by admin

CamOdoCal: Automatic Intrinsic and Extrinsic Calibration of a Rig with Multiple Generic Cameras and Odometry

July 18, 2013 in ETHZ-CVG, Publications, year 3 by admin

Lionel Heng, Bo Li, and Marc Pollefeys

2013 IEEE/RSJ International Conference on Intelligent Robots and Systems
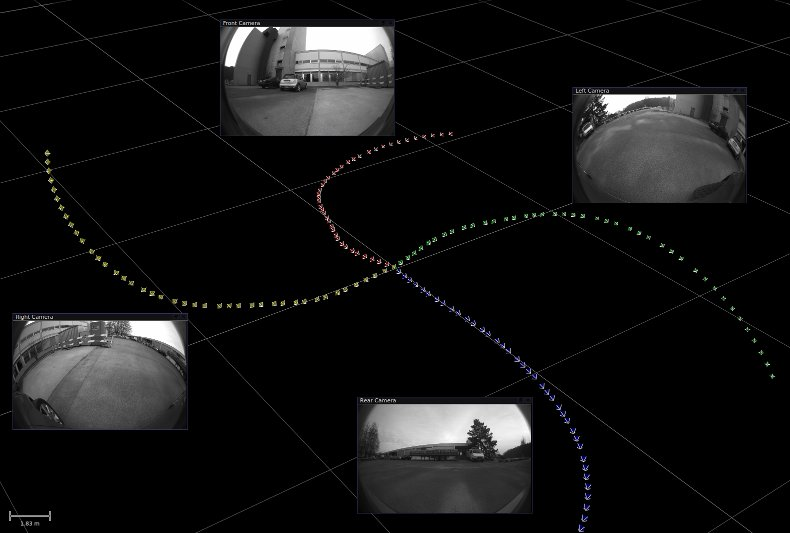
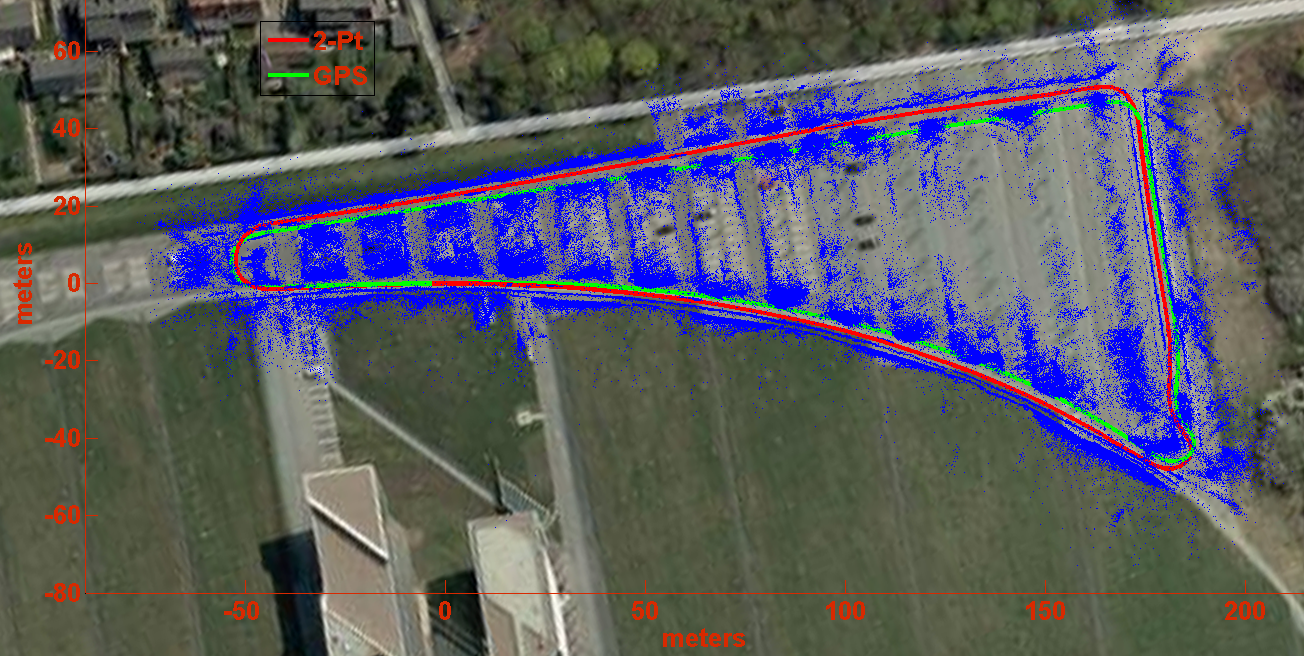
Multiple cameras are increasingly prevalent on robotic and human-driven vehicles. These cameras come in a variety of wide-angle, fish-eye, and catadioptric models. Furthermore, wheel odometry is generally available on the vehicles on which the cameras are mounted. For robustness, vision applications tend to use wheel odometry as a strong prior for camera pose estimation, and in these cases, an accurate extrinsic calibration is required in addition to an accurate intrinsic calibration. To date, there is no known work on automatic intrinsic calibration of generic cameras, and more importantly, automatic extrinsic calibration of a rig with multiple generic cameras and odometry.

We propose an easy-to-use automated pipeline that handles both intrinsic and extrinsic calibration; we do not assume that there are overlapping fields of view. At the begining, we run an intrinsic calibration for each generic camera. The intrinsic calibration is automatic and requires a chessboard. Subsequently, we run an extrinsic calibration which finds all camera-odometry transforms. The extrinsic calibration is unsupervised, uses natural features, and only requires the vehicle to be driven around for a short time. The intrinsic parameters are optimized in a final bundle adjustment step in the extrinsic calibration. In addition, the pipeline produces a globally-consistent sparse map of landmarks which can be used for visual localization. The pipeline is publicly available as a standalone C++ package.


@inproceedings{hengIROS13,
author = {Lionel Heng and
Bo Li and
Marc Pollefeys},
title = {CamOdoCal: Automatic Intrinsic and Extrinsic Calibration of a Rig with Multiple Generic Cameras and Odometry},
booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
year = {2013},
pages = {}
}
Article full text

by admin

Robust Pose-Graph Loop-Closures with Expectation-Maximization

July 18, 2013 in ETHZ-CVG, Publications, year 3 by admin

Gim Hee Lee, Friedrich Fraundorfer, and Marc Pollefeys

2013 IEEE/RSJ International Conference on Intelligent Robots and Systems

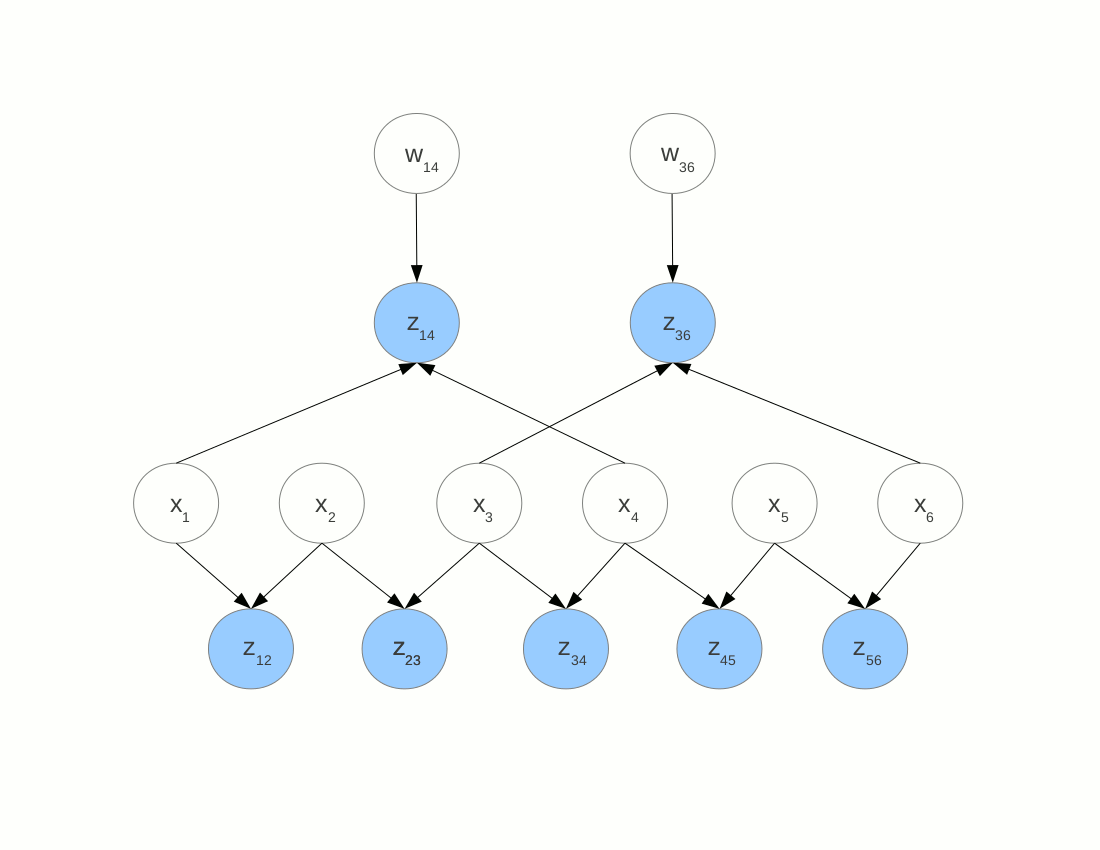
In this paper, we model the robust loop-closure pose-graph SLAM problem as a Bayesian network and show that it can be solved with the Classification Expectation-Maximization (EM) algorithm.
In particular, we express our robust pose-graph SLAM as a Bayesian network where the robot poses and constraints are latent and observed variables. An additional set of latent variables is introduced as weights for the loop-constraints. We show that the weights can be chosen as the Cauchy function, which are iteratively computed from the errors between the predicted robot poses and observed loop-closure constraints in the Expectation step, and used to weigh the cost functions from the pose-graph loop-closure constraints in the Maximization step. As a result, outlier loop-closure constraints are assigned low weights and exert less influences in the pose-graph optimization within the EM iterations.
We show proofs of the conceptual similarity between our EM algorithm and the M-Estimator. Specifically, we show that the weight function in our EM algorithm is equivalent to the robust residual function in the M-Estimator. We verify our proposed algorithm with experimental results from multiple simulated and real-world datasets, and comparisons with other +existing works.


@inproceedings{IROS13_Lee_Robust,
author = {Gim Hee Lee and
Friedrich Faundorfer and
Marc Pollefeys},
title = {Robust Pose-Graph Loop-Closures with Expectation-Maximization},
booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
year = {2013},
pages = {}
}
Article full text

by admin

Structureless Pose-Graph Loop-Closure with a Multi-Camera System on a Self-Driving Car

July 18, 2013 in ETHZ-CVG, Publications, year 3 by admin

Gim Hee Lee, Friedrich Fraundorfer, Marc Pollefeys

2013 IEEE/RSJ International Conference on Intelligent Robots and Systems

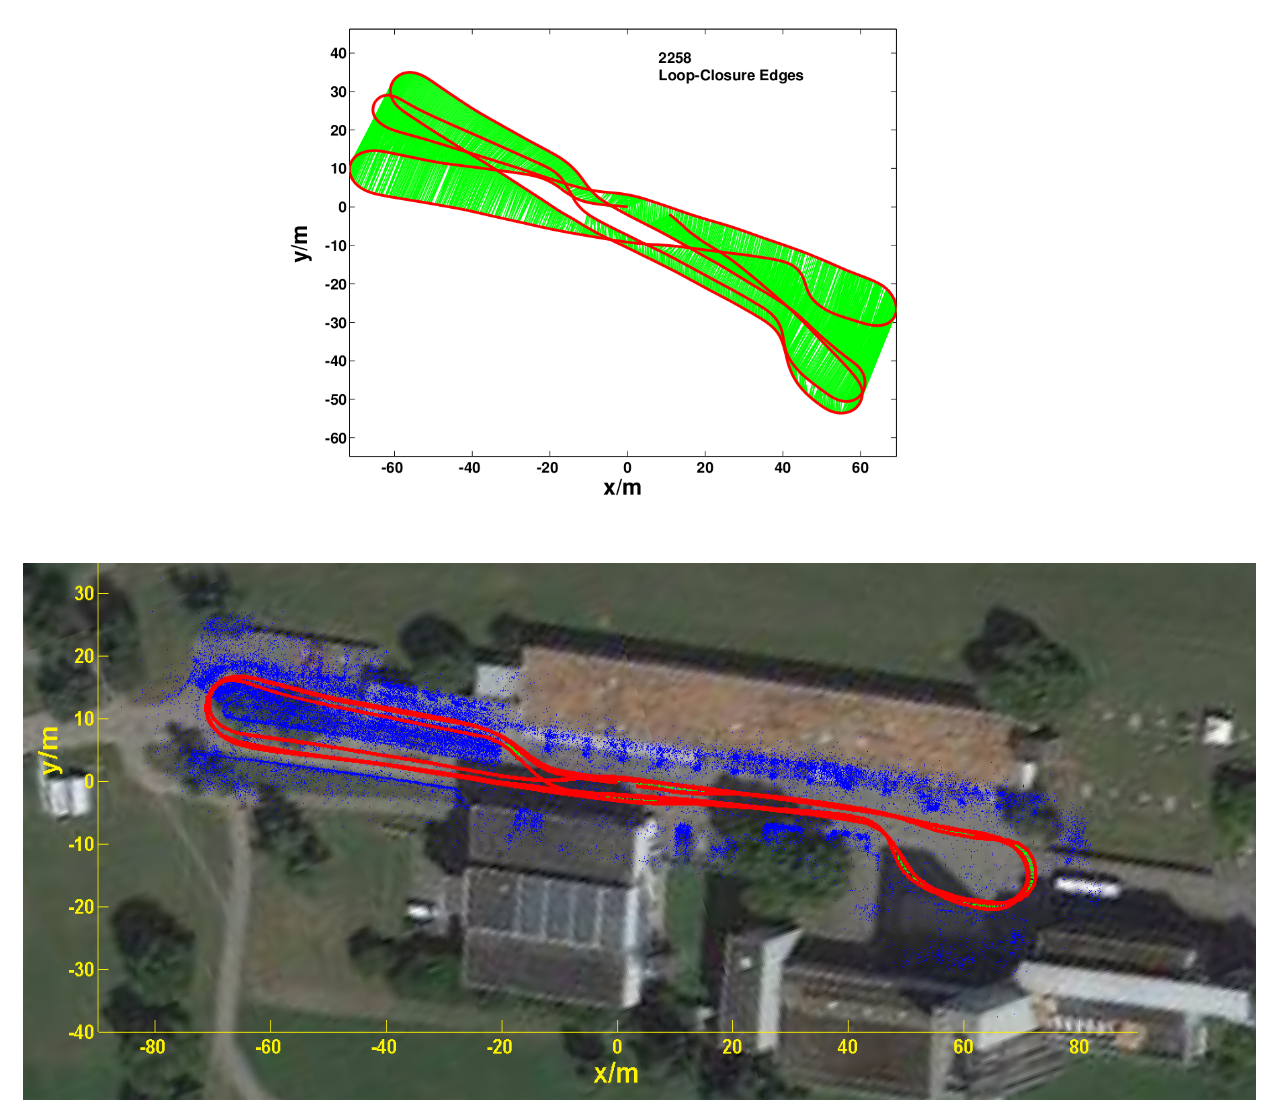
In this paper, we propose a method to compute the pose-graph loop-closure constraints using multiple non/minimal overlapping field-of-views cameras mounted rigidly on a self-driving car without the need to reconstruct any 3D scene points.
In particular, we show that the relative pose with metric scale between two loop-closing pose-graph vertices can be directly obtained from the epipolar geometry of the multi-cameras system. As a result, we avoid the additional time complexities and uncertainties from the reconstruction of 3D scene points which are needed by standard monocular and stereo approaches. In addition, there is a greater flexibility in choosing a configuration for the multi-camera system to cover a wider field-of-view so as to avoid missing out any loop-closure opportunities.
We show that by expressing the point correspondences between two frames as Pluecker lines and enforcing the planar motion constraint on the car, we are able to use multiple cameras as one and formulate the relative pose problem for loop-closure as a minimal problem which requires 3-point correspondences that yields up to six real solutions. The RANSAC algorithm isused to determine the correct solution and for robust estimation. We verify our method with results from multiple large-scale real-world data.


@inproceedings{IROS13_Lee_Structureless,
author = {Gim Hee Lee and
Friedrich Faundorfer and
Marc Pollefeys},
title = {Structureless Pose-Graph Loop-Closure with a Multi-Camera System on a Self-Driving Car},
booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
year = {2013},
pages = {}
}
Article full text

by admin

Toward Automated Driving in Cities using Close-to-Market Sensors, an Overview of the V-Charge Project

July 1, 2013 in Bosch, ETHZ-ASL, ETHZ-CVG, Oxford-MRG, Parma-Vislab, Publications, TUB, VW by admin

Paul Furgale et al.

IEEE Intelligent Vehicles Symposium (IVS) 2013

Future requirements for drastic reduction of CO2 production and energy consumption will lead to significant changes in the way we see mobility in the years to come.

However, the automotive industry has identified significant barriers to the adoption of electric vehicles, including reduced driving range and greatly increased refueling times. Automated cars have the potential to reduce the environmental impact of driving, and increase the safety of motor vehicle travel. The current state-of-the-art in vehicle automation requires a suite of expensive sensors. While the cost of these sensors is decreasing, integrating them into electric cars will increase the price and represent another barrier to adoption.

The V-Charge Project, funded by the European Commission, seeks to address these problems simultaneously by developing an electric automated car, outfitted with close-to-market sensors, which is able to automate valet parking and recharging for integration into a future transportation system. The final goal is the demonstration of a fully operational system including automated navigation and parking.

This paper presents an overview of the V-Charge system, from the platform setup to the mapping, perception, and planning sub-systems.


@inproceedings{furgale_iv13,
Address = {Gold Coast, Australia},
Annote = {full-conf-pb},
Author = {Paul Furgale and Ulrich Schwesinger and Martin Rufli and Wojciech Derendarz and Hugo Grimmett and Peter M\"{u}hlfellner and Stefan Wonneberger and Julian Timpner Stephan Rottmann and Bo Li and Bastian Schmidt and Thien Nghia Nguyen and Elena Cardarelli and Stefano Cattani and Stefan Br\"{u}ning and Sven Horstmann and Martin Stellmacher and Holger Mielenz and Kevin K\"{o}ser and Markus Beermann and Christian H\"{a}ne and Lionel Heng and Gim Hee Lee and Friedrich Fraundorfer and Ren\'{e} Iser and Rudolph Triebel and Ingmar Posner and Paul Newman and Lars Wolf and Marc Pollefeys and Stefan Brosig and Jan Effertz and C\'edric Pradalier and Roland Siegwart},
Booktitle = {IEEE Intelligent Vehicles Symposium (IV)},
Month = {23--26 June},
Pages = {809--816},
Title = {{Toward Automated Driving in Cities using Close-to-Market Sensors, an Overview of the V-Charge Project}},
Year = {2013}
}

Article full text

by admin

A Patch Prior for Dense 3D Reconstruction in Man-Made Environments

May 31, 2013 in ETHZ-CVG, Publications, year 2 by admin

Christian Haene, Christopher Zach, Bernhard Zeisl, and Marc Pollefeys

2012 2nd International Conference on 3D Imaging, Modeling, Processing, Visualization & Transmission

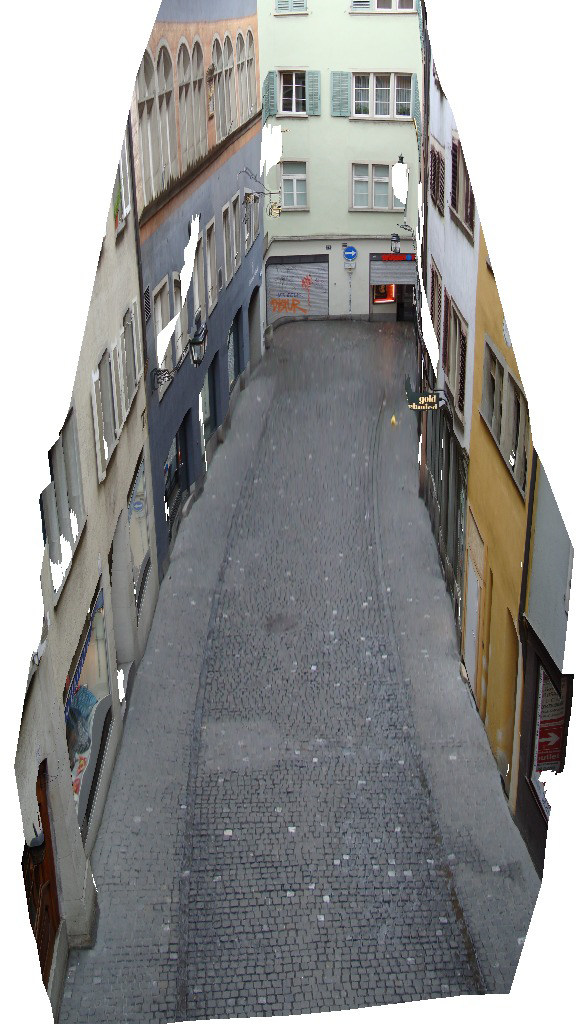
Dense 3D reconstruction in man-made environments has to contend with weak and ambiguous observations due to texture-less surfaces which are predominant in such environments. This challenging task calls for strong, domain-specific priors. These are usually modeled via regularization or smoothness assumptions. Generic smoothness priors, e.g. total variation are often not sufficient to produce convincing results. Consequently, we propose a more powerful prior directly modeling the expected local surface-structure, without the need to utilize expensive methods such as higher-order MRFs. Our approach is inspired by patch-based representations used in image processing. In contrast to the over-complete dictionaries used e.g. for sparse representations our patch dictionary is much smaller. The proposed energy can be optimized by utilizing an efficient first-order primal dual algorithm. Our formulation is in particular very natural to model priors on the 3D structure of man-made environments. We demonstrate the applicability of our prior on synthetic data and on real data, where we recover dense, piece-wise planar 3D models using stereo and fusion of multiple depth images.


@inproceedings{haene3DIMPVT13,
author = {Christian Haene and Christopher Zach and Bernhard Zeisl and Marc Pollefeys},
title = {A Patch Prior for Dense 3D Reconstruction in Man-Made Environments},
booktitle = {3DIMPVT},
year = {2013},
pages = {}
}
Article full text

by admin

Joint 3D Scene Reconstruction and Class Segmentation

May 31, 2013 in ETHZ-CVG, Publications by admin

Christian Haene, Christopher Zach, Andrea Cohen, Roland Angst, and Marc Pollefeys

2013 IEEE Conference on Computer Vision and Pattern Recognition

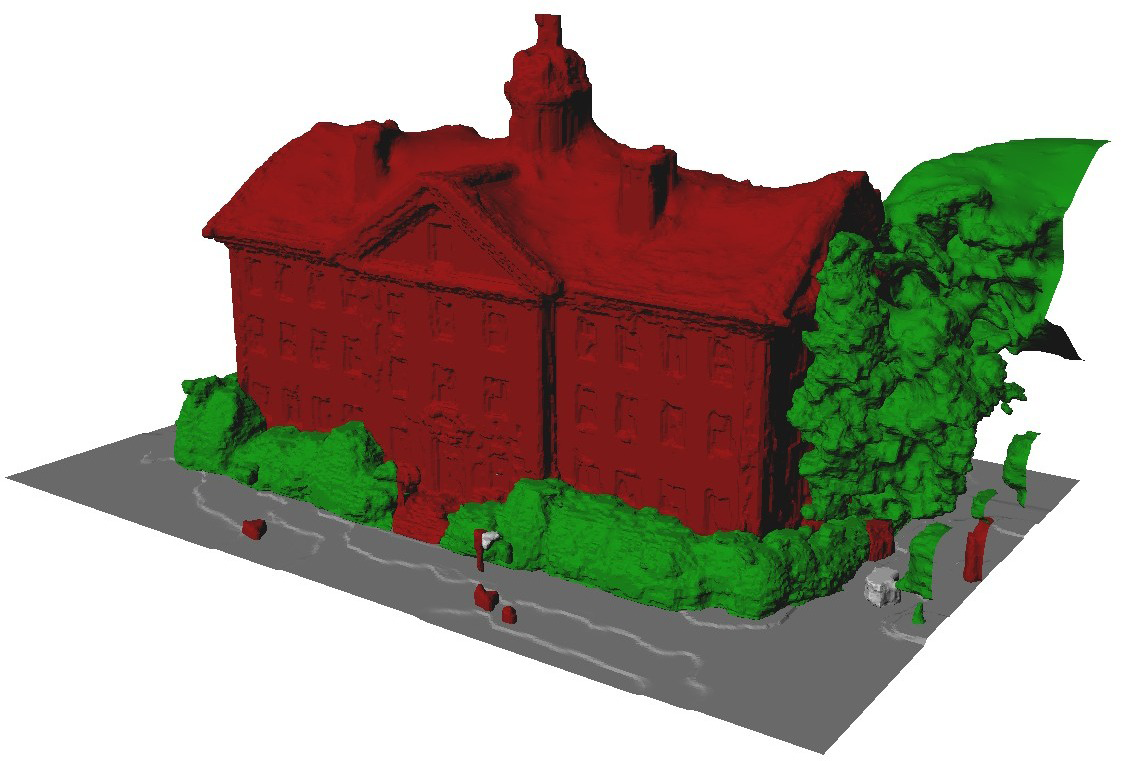
Both image segmentation and dense 3D modeling from images represent an intrinsically ill-posed problem. Strong regularizers are therefore required to constrain the solutions from being ‘too noisy’. Unfortunately, these priors generally yield overly smooth reconstructions and/or segmentations in certain regions whereas they fail in other areas to constrain the solution sufficiently. In this paper we argue that image segmentation and dense 3D reconstruction contribute valuable information to each other’s task. As a consequence, we propose a rigorous mathematical framework to formulate and solve a joint segmentation and dense reconstruction problem. Image segmentations provide geometric cues about which surface orientations are more likely to appear at a certain location in space whereas a dense 3D reconstruction yields a suitable regularization for the segmentation problem by lifting the labeling from 2D images to 3D space. We show how appearance-based cues and 3D surface orientation priors can be learned from training data and subsequently used for class-specific regularization. Experimental results on several real data sets highlight the advantages of our joint formulation


@inproceedings{haeneCVPR13,
author = {Christian Haene and
Christopher Zach and
Andrea Cohen and
Roland Angst and
Marc Pollefeys},
title = {Joint 3D Scene Reconstruction and Class Segmentation},
booktitle = {CVPR},
year = {2013},
pages = {}
}
Article full text

by admin

Motion Estimation for a Self-Driving Car with a Generalized Camera

May 31, 2013 in ETHZ-CVG, Publications by admin

Gim Hee Lee, Friedrich Fraundorfer, and Marc Pollefeys

2013 IEEE Conference on Computer Vision and Pattern Recognition

In this paper, we present a visual ego-motion estima tion algorithm for a self-driving car equipped with a close to-market multi-camera system. By modeling the multi-camera system as a generalized camera and applying the non-holonomic motion constraint of a car, we show that this leads to a novel 2-point minimal solution for the generalized essential matrix where the full relative motion including metric scale can be obtained. We provide the analytical solutions for the general case with at least one inter-camera correspondence and a special case with only intra-camera correspondences. We show that up to a maximum of 6 solutions exist for both cases. We identify the existence of degeneracy when the car undergoes straight motion in the special case with only intra-camera correspondences where the scale becomes unobservable and provide a practical al ternative solution. Our formulation can be efficiently implemented within RANSAC for robust estimation. We verify the validity of our assumptions on the motion model by comparing our results on a large real-world dataset collected by a car equipped with 4 cameras with minimal overlapping field-of-views against the GPS/INS ground truth.


@inproceedings{leeCVPR13,
author = {Gim Hee Lee and Friedrich Fraundorfer and Marc Pollefeys},
title = {Motion Estimation for a Self-Driving Car with a Generalized Camera},
booktitle = {CVPR},
year = {2013}
}

Article full text