 by
Structureless Pose-Graph Loop-Closure with a Multi-Camera System on a Self-Driving Car
July 18, 2013 in ETHZ-CVG, Publications, year 3 by admin
Gim Hee Lee, Friedrich Fraundorfer, Marc Pollefeys
2013 IEEE/RSJ International Conference on Intelligent Robots and Systems
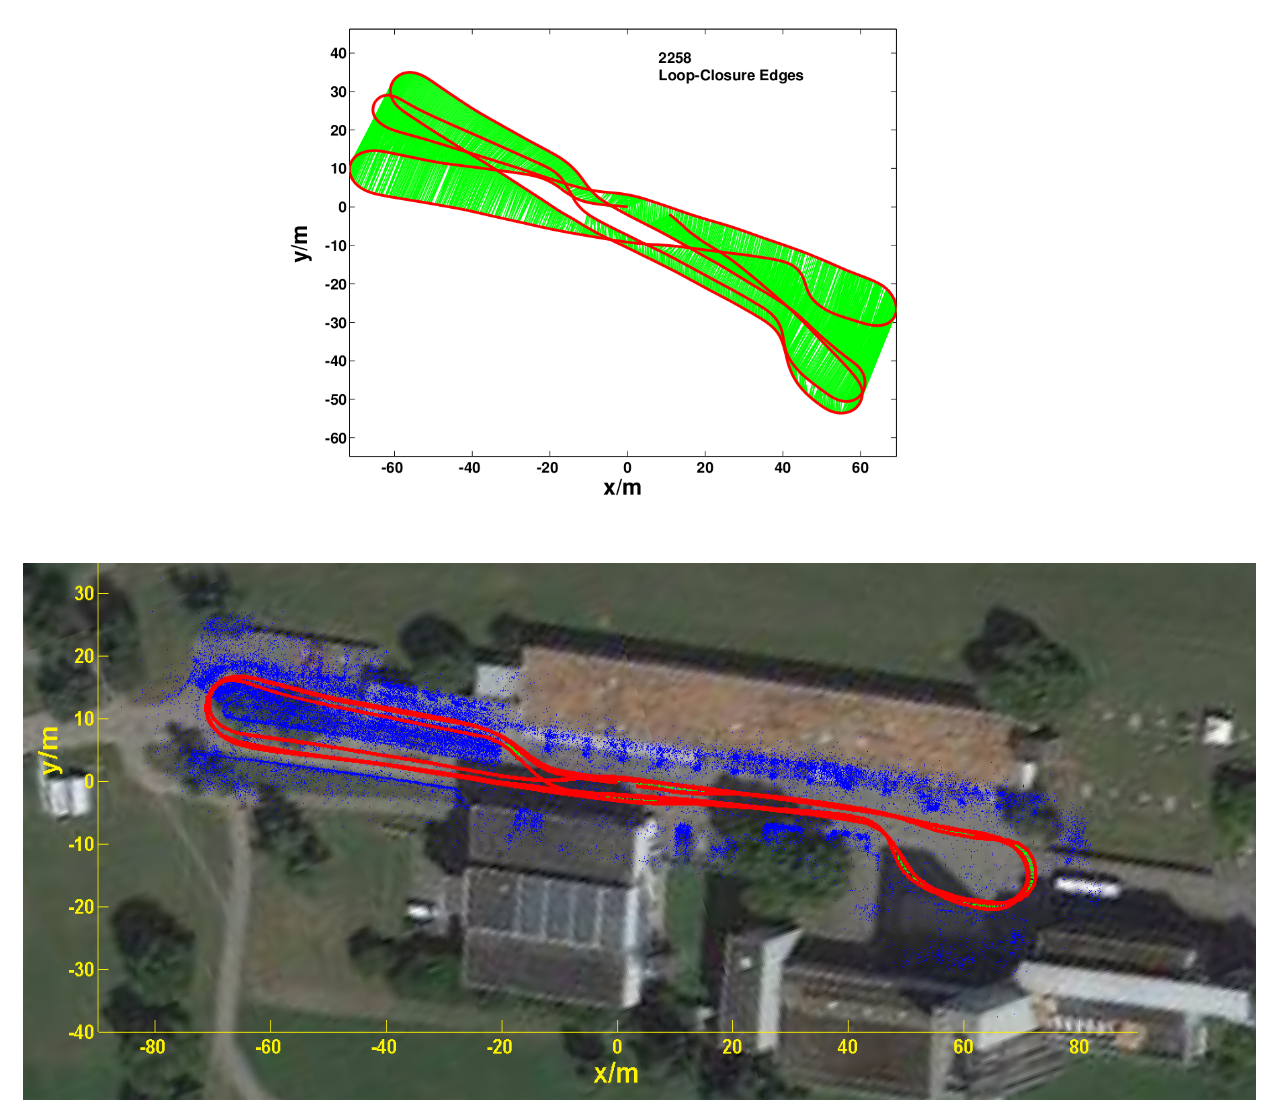 In this paper, we propose a method to compute the pose-graph loop-closure constraints using multiple non/minimal overlapping field-of-views cameras mounted rigidly on a self-driving car without the need to reconstruct any 3D scene points.
In particular, we show that the relative pose with metric scale between two loop-closing pose-graph vertices can be directly obtained from the epipolar geometry of the multi-cameras system. As a result, we avoid the additional time complexities and uncertainties from the reconstruction of 3D scene points which are needed by standard monocular and stereo approaches. In addition, there is a greater flexibility in choosing a configuration for the multi-camera system to cover a wider field-of-view so as to avoid missing out any loop-closure opportunities.
We show that by expressing the point correspondences between two frames as Pluecker lines and enforcing the planar motion constraint on the car, we are able to use multiple cameras as one and formulate the relative pose problem for loop-closure as a minimal problem which requires 3-point correspondences that yields up to six real solutions. The RANSAC algorithm isused to determine the correct solution and for robust estimation. We verify our method with results from multiple large-scale real-world data.
                      @inproceedings{IROS13_Lee_Structureless,

                      author = {Gim Hee Lee and

                      Friedrich Faundorfer and

                      Marc Pollefeys},

                      title = {Structureless Pose-Graph Loop-Closure with a Multi-Camera System on a Self-Driving Car},

                      booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},

                      year = {2013},

                      pages = {}

                      }


