Summary maps for lifelong visual localization

November 13, 2015 in ETHZ-ASL, Journals, Publications, VW, year 4 by Ulrich Schwesinger

Peter Muehlfellner, Mathias Buerki, Michael Bosse, Wojciech Derendarz, Roland Philippsen and Paul Furgale

Journal of Field Robotics
Robots that use vision for localization need to handle environments which are subject to
seasonal and structural change, and operate under changing lighting and weather conditions.
We present a framework for lifelong localization and mapping designed to provide
robust and metrically accurate online localization in these kinds of changing environments.
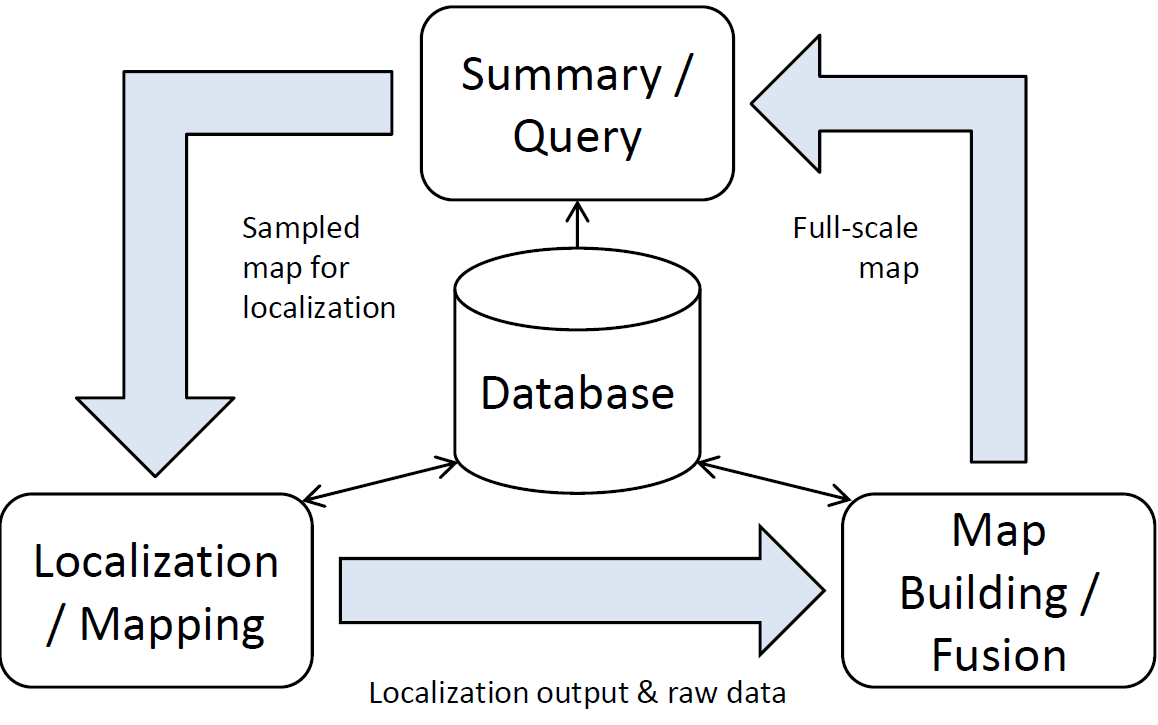
Our system iterates between offline map building, map summary, and online localization.
The offline mapping fuses data from multiple visually varied datasets, thus dealing with
changing environments by incorporating new information. Before passing this data to the
online localization system, the map is summarized, selecting only the landmarks that are
deemed useful for localization. This Summary Map enables online localization that is accurate
and robust to the variation of visual information in natural environments while still
being computationally efficient.

We present a number of summary policies for selecting useful features for localization from
the multi-session map and explore the tradeoff between localization performance and computational
complexity. The system is evaluated on 77 recordings, with a total length of 30
kilometers, collected outdoors over sixteen months. These datasets cover all seasons, various
times of day, and changing weather such as sunshine, rain, fog, and snow. We show that it
is possible to build consistent maps that span data collected over an entire year, and cover
day-to-night transitions. Simple statistics computed on landmark observations are enough
to produce a Summary Map that enables robust and accurate localization over a wide range
of seasonal, lighting, and weather conditions.

@article{muhlfellner2015summary,
title={Summary maps for lifelong visual localization},
author={M{\"u}hlfellner, Peter and B{\"u}rki, Mathias and Bosse, Mike and Derendarz, Wojciech and Philippsen, Roland and Furgale, Paul},
journal={Journal of Field Robotics},
year={2015},
publisher={John Wiley \& Sons}
}

by admin
Evaluation of Fisheye-Camera Based Visual Multi-Session Localization in a Real-World Scenario

September 20, 2013 in ETHZ-ASL, Publications, VW, year 3 by admin

Peter Muehlfellner, Paul Furgale, Wojciech Derendarz, Roland Philippsen

IEEE Intelligent Vehicles Symposium (IVS) 2013

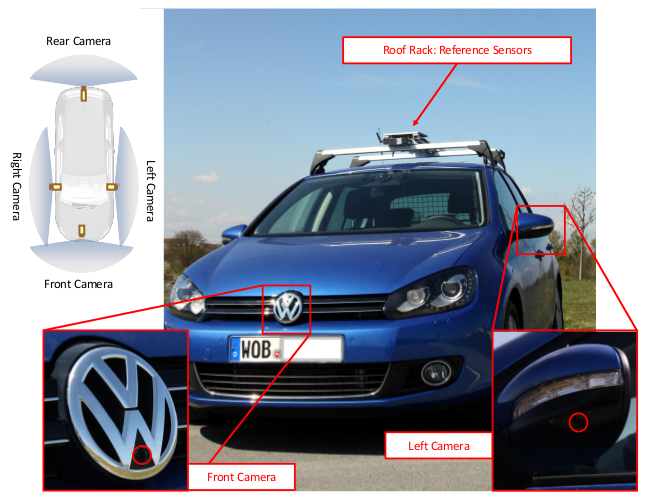
The V-Charge Golf, showing its integrated sensors and the very subtle differences to a regular “consumer car”.

The European V-Charge project seeks to develop fully automated valet parking and charging of electric vehicles using only low-cost sensors. One of the challenges is to implement robust visual localization using only cameras and stock vehicle sensors. We integratedfour monocular, wide-angle, fisheye cameras on a consumer car and implemented a mapping and localization pipeline. Visual features and odometry are combined to build and localize against a keyframe-based three dimensional map. We report results for the first stage of the project, based on two months worth of data acquired under varying conditions, with the objective of localizing against a map created offline.


@inproceedings{fisheye_iv13,
Address = {Gold Coast, Australia},
Author = {Peter Muehlfellner AND Paul Furgale AND Wojciech Derendarz AND Roland Philippsen},
Booktitle = {IEEE Intelligent Vehicles Symposium (IV)},
Month = jun,
Pages = {57--62},
Title = {{Evaluation of Fisheye-Camera Based Visual Multi-Session Localization in a Real-World Scenario}},
Year = {2013}
}

Article full text

by admin

Toward Automated Driving in Cities using Close-to-Market Sensors, an Overview of the V-Charge Project

July 1, 2013 in Bosch, ETHZ-ASL, ETHZ-CVG, Oxford-MRG, Parma-Vislab, Publications, TUB, VW by admin

Paul Furgale et al.

IEEE Intelligent Vehicles Symposium (IVS) 2013

Future requirements for drastic reduction of CO2 production and energy consumption will lead to significant changes in the way we see mobility in the years to come.

However, the automotive industry has identified significant barriers to the adoption of electric vehicles, including reduced driving range and greatly increased refueling times. Automated cars have the potential to reduce the environmental impact of driving, and increase the safety of motor vehicle travel. The current state-of-the-art in vehicle automation requires a suite of expensive sensors. While the cost of these sensors is decreasing, integrating them into electric cars will increase the price and represent another barrier to adoption.

The V-Charge Project, funded by the European Commission, seeks to address these problems simultaneously by developing an electric automated car, outfitted with close-to-market sensors, which is able to automate valet parking and recharging for integration into a future transportation system. The final goal is the demonstration of a fully operational system including automated navigation and parking.

This paper presents an overview of the V-Charge system, from the platform setup to the mapping, perception, and planning sub-systems.


@inproceedings{furgale_iv13,
Address = {Gold Coast, Australia},
Annote = {full-conf-pb},
Author = {Paul Furgale and Ulrich Schwesinger and Martin Rufli and Wojciech Derendarz and Hugo Grimmett and Peter M\"{u}hlfellner and Stefan Wonneberger and Julian Timpner Stephan Rottmann and Bo Li and Bastian Schmidt and Thien Nghia Nguyen and Elena Cardarelli and Stefano Cattani and Stefan Br\"{u}ning and Sven Horstmann and Martin Stellmacher and Holger Mielenz and Kevin K\"{o}ser and Markus Beermann and Christian H\"{a}ne and Lionel Heng and Gim Hee Lee and Friedrich Fraundorfer and Ren\'{e} Iser and Rudolph Triebel and Ingmar Posner and Paul Newman and Lars Wolf and Marc Pollefeys and Stefan Brosig and Jan Effertz and C\'edric Pradalier and Roland Siegwart},
Booktitle = {IEEE Intelligent Vehicles Symposium (IV)},
Month = {23--26 June},
Pages = {809--816},
Title = {{Toward Automated Driving in Cities using Close-to-Market Sensors, an Overview of the V-Charge Project}},
Year = {2013}
}

Article full text