 by
Introspective Active Learning for Scalable Semantic Mapping
July 2, 2013 in Oxford-MRG, Publications, year 3 by admin
Rudolph Triebel, Hugo Grimmett, Rohan Paul, Ingmar Posner
Workshop. Robotics Science and Systems (RSS)
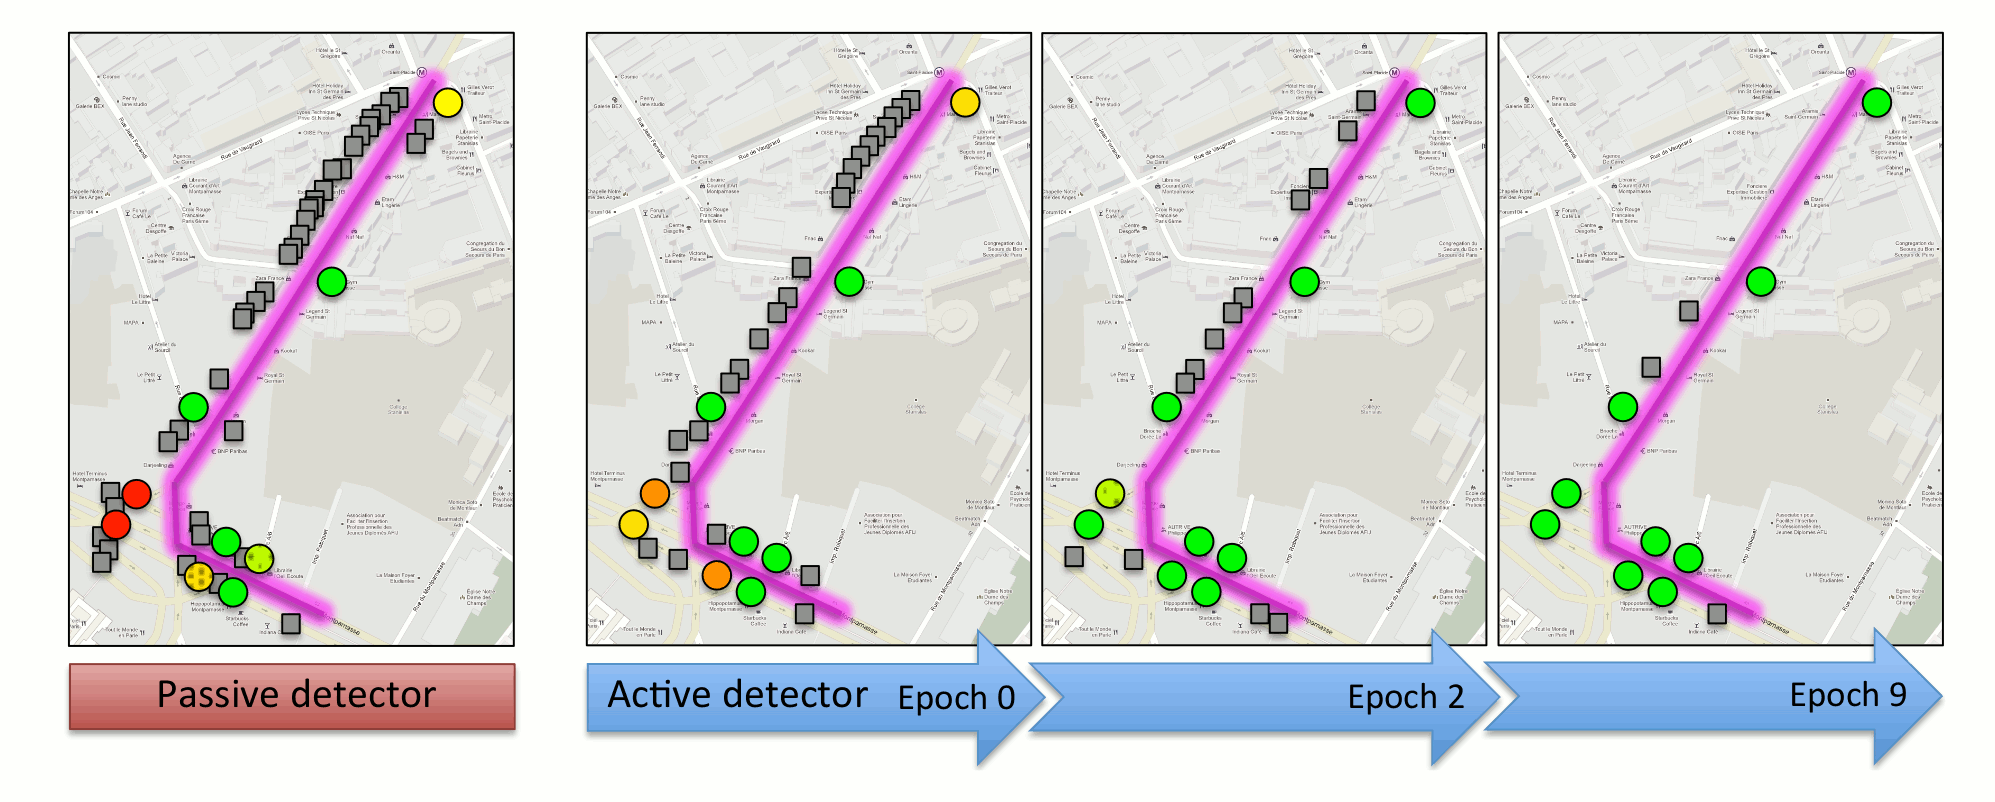 This paper proposes an active learning framework for semantic mapping in mobile robotics. In particular, our work explores the benefits of an introspective classifier over that of a more traditional non-introspective approach for active data selection. We extend the notion of introspection to a particular sparse Gaussian Process classifier, the Informative Vector Machine (IVM), and show that the use of an IVM leads to more informative questions being asked during active learning. We further leverage the information-theoretic nature of the IVM to formulate a principled mechanism for forgetting stale data. The result is an efficient and highly effective end-to-end active learning framework which outperforms both passive approaches as well as active approaches based on the more commonly used Support Vector Machine (SVM) in terms of classification performance and learning rate on a publicly available dataset.
                      @INPROCEEDINGS { TriebelRSSWorkshop2013,

                      AUTHOR = { Rudolph Triebel, Hugo Grimmett, Rohan Paul, Ingmar Posner },

                      BOOKTITLE = { Workshop. Robotics Science and Systems (RSS) },

                      MONTH = jun,

                      TITLE = {Introspective Active Learning for Scalable Semantic Mapping },

                      YEAR = { 2013 },

                      }


