 by
Robust Pose-Graph Loop-Closures with Expectation-Maximization
July 18, 2013 in ETHZ-CVG, Publications, year 3 by admin
Gim Hee Lee, Friedrich Fraundorfer, and Marc Pollefeys
2013 IEEE/RSJ International Conference on Intelligent Robots and Systems
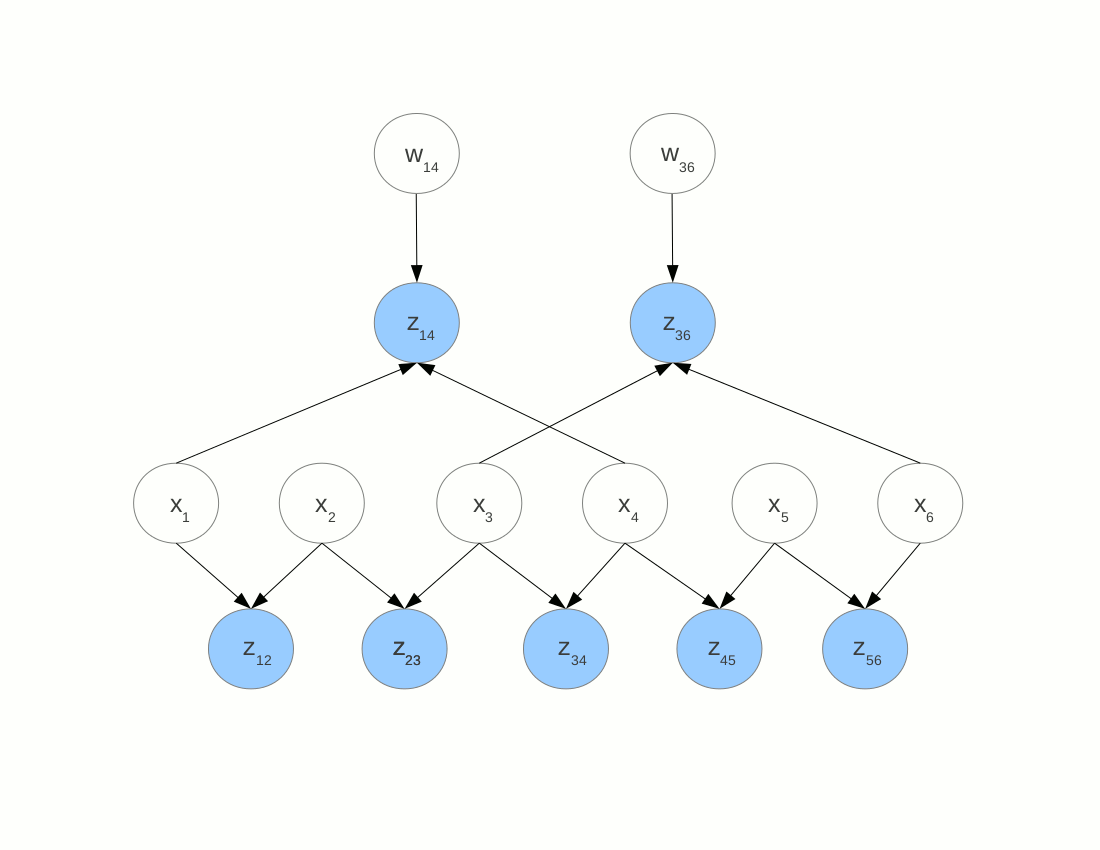 In this paper, we model the robust loop-closure pose-graph SLAM problem as a Bayesian network and show that it can be solved with the Classification Expectation-Maximization (EM) algorithm.
In particular, we express our robust pose-graph SLAM as a Bayesian network where the robot poses and constraints are latent and observed variables. An additional set of latent variables is introduced as weights for the loop-constraints. We show that the weights can be chosen as the Cauchy function, which are iteratively computed from the errors between the predicted robot poses and observed loop-closure constraints in the Expectation step, and used to weigh the cost functions from the pose-graph loop-closure constraints in the Maximization step. As a result, outlier loop-closure constraints are assigned low weights and exert less influences in the pose-graph optimization within the EM iterations.
We show proofs of the conceptual similarity between our EM algorithm and the M-Estimator. Specifically, we show that the weight function in our EM algorithm is equivalent to the robust residual function in the M-Estimator. We verify our proposed algorithm with experimental results from multiple simulated and real-world datasets, and comparisons with other +existing works.
                      @inproceedings{IROS13_Lee_Robust,

                      author = {Gim Hee Lee and

                      Friedrich Faundorfer and

                      Marc Pollefeys},

                      title = {Robust Pose-Graph Loop-Closures with Expectation-Maximization},

                      booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},

                      year = {2013},

                      pages = {}

                      }


